Newton-Leipnik
3-D flow ·
#newtonleipnik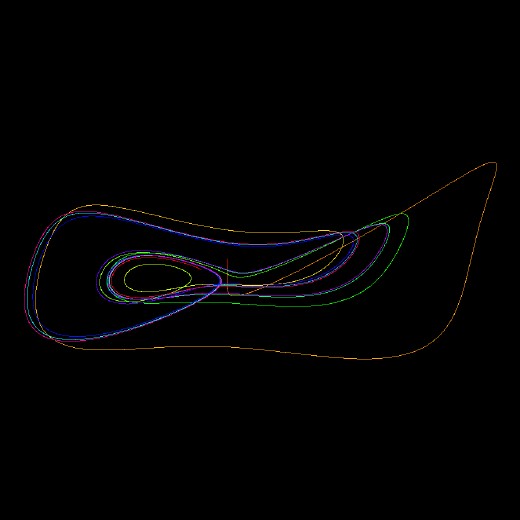
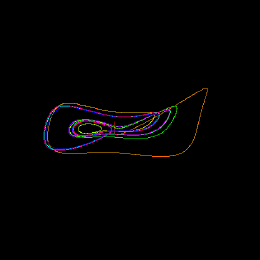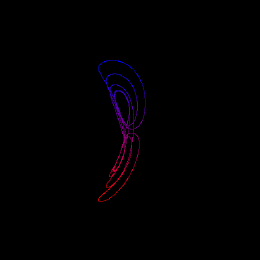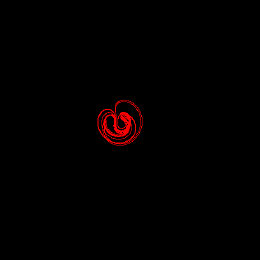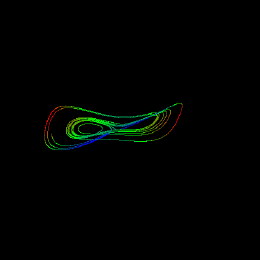
Newton–Leipnik Attractor — Arises from a rigid-body rotation model with a linear feedback torque; it has two coexisting scroll-shaped attractors.
dx/dt = −ax + y + 10yz
dy/dt = −x − 0.4y + 5xz
dz/dt = bz − 5xy
Open Newton-Leipnik in chaosrack →
It opens running, on the model selector, with its own knobs. Rotate it by dragging, zoom with the wheel, and turn the parameters to see what the figure does when the system changes.